|
Jiajun JIANG I'm a third-year Ph.D. student at the ROAS Thrust, HKUST(GZ) in Guangzhou, China. Prior to that, I received both my bachelor's and master's degrees from Zhejiang University and was advised by Prof. Yu Zhang. I previously worked as an algorithm engineer at the Autonomous Driving Lab, Alibaba Group in Hangzhou, China, focusing on autonomous driving. I'm currently supervised by Prof. Jie Song and Prof. Ping Tan. |
|
News2025/05/29 Academic page is online! |
ResearchMy current research mainly focuses on robot mapping and navigation. |
|
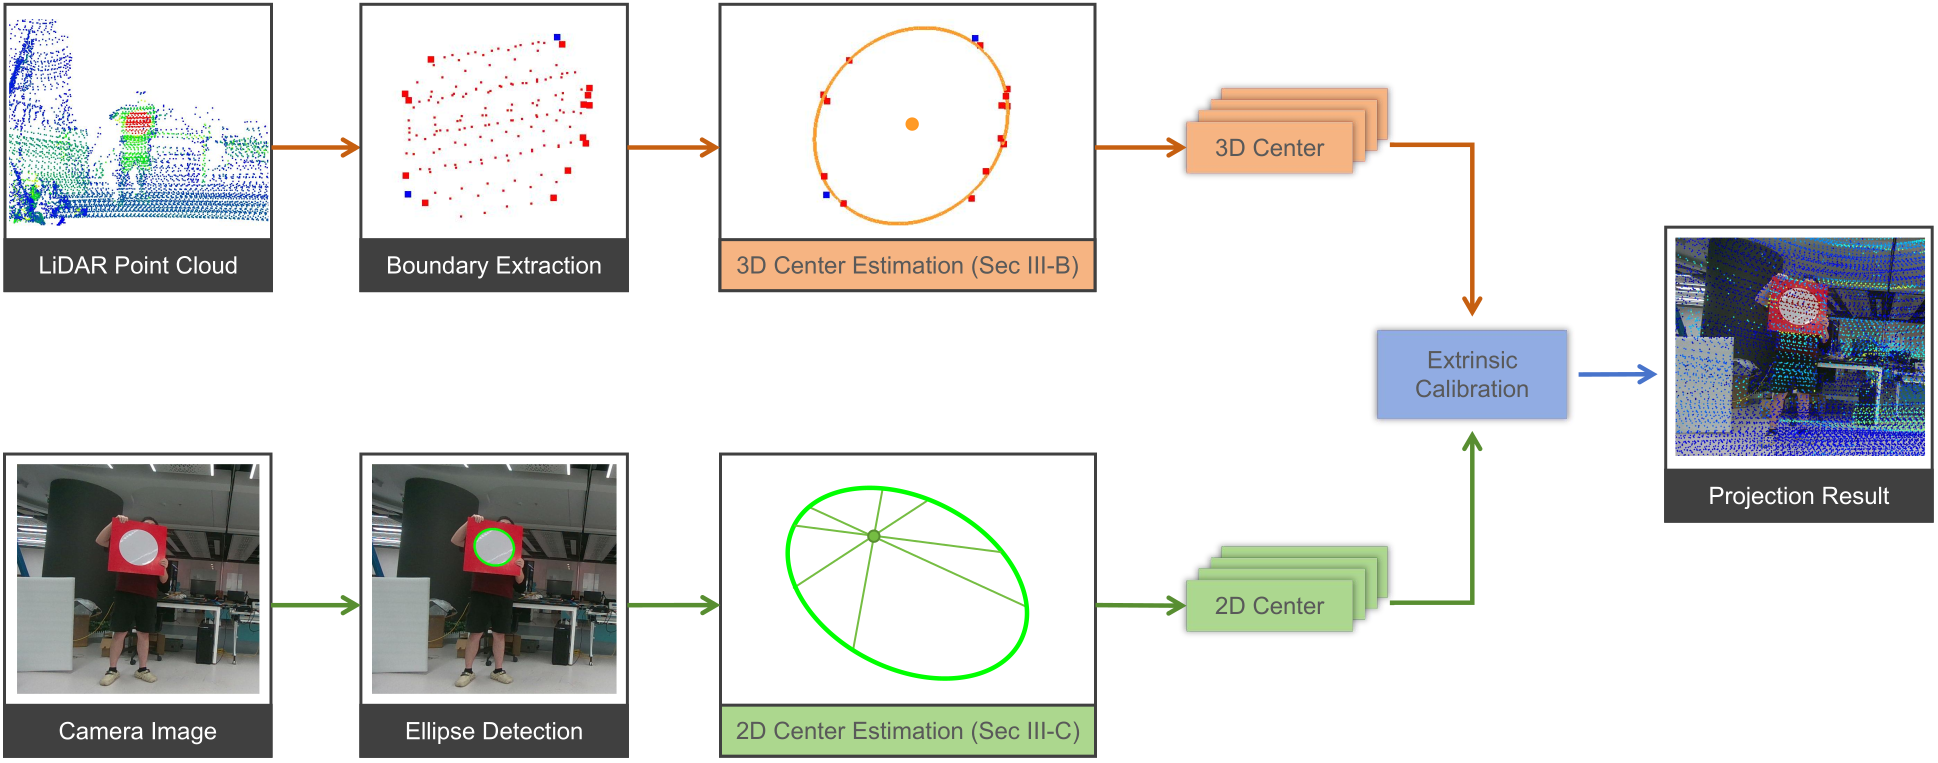
Accurate Measurement of 3D and 2D Circular Centers With Application to LiDAR-Camera Extrinsic Calibration
Jiajun Jiang, Xiao Hu, Wancheng Liu, Wei Jiang IEEE TIM (2026) project page / paper / code Accurate 3D circular-center and 2D projected-center measurement for LiDAR-camera extrinsic calibration. |

|
DualMap: Online Open-Vocabulary Semantic Mapping for Natural Language Navigation in Dynamic Changing Scenes
Jiajun Jiang, Yiming Zhu, Zirui Wu, Jie Song^ RA-L (2025) project page / video / paper / arXiv / code DualMap is a novel online open-vocabulary mapping system that enables robots to understand and navigate dynamically changing environments through natural language queries. |

|
Thermal-Inertial SLAM for the Environments with Challenging Illumination
Jiajun Jiang, Xingxin Chen, WeiChen Dai, Zelin Gao, Yu Zhang^ RA-L (2022) paper A thermal-inertial SLAM system for all-day autonomous systems |